|
Hormodular 1.0
Locomotion gait discovery by using digital hormones on modular robots
|
|
Hormodular 1.0
Locomotion gait discovery by using digital hormones on modular robots
|
Loads custom-made registry entries to the ECF. {
//-- Get the robot values from the registry:
//-----------------------------------------------------------------------------------------
//-- Number of modules:
voidP sptr = state->getRegistry()->getEntry("robot.modules");
n_modules = *((uint*) sptr.get() );
std::cout << "[Evolve] Info: Loaded \"robot.modules\"="<< n_modules << std::endl;
//-- Max runtime:
sptr = state->getRegistry()->getEntry("robot.runtime");
max_runtime =(unsigned long) *((uint*) sptr.get() );
std::cout << "[Evolve] Info: Loaded \"robot.runtime\"="<< max_runtime << std::endl;
//-- Time step:
sptr = state->getRegistry()->getEntry("robot.timestep");
timestep = *((float*) sptr.get() );
std::cout << "[Evolve] Info: Loaded \"robot.timestep\"="<< timestep << std::endl;
//-- Gait table file:
sptr = state->getRegistry()->getEntry("robot.configfile");
config_file = *((std::string*) sptr.get() );
std::cout << "[Evolve] Info: Loaded \"robot.configfile\"="<< config_file << std::endl;
//-- Get the oscillator parameters from the registry:
//---------------------------------------------------------------------------------------
//-- Max amplitude:
sptr = state->getRegistry()->getEntry("osc.maxamplitude");
int max_amplitude = *((uint*) sptr.get());
max_amp_0_5 = max_amplitude / 2.0;
std::cout << "[Evolve] Info: Loaded \"osc.maxamplitude\"="<< max_amplitude << std::endl;
//-- Max offset:
sptr = state->getRegistry()->getEntry("osc.maxoffset");
max_offset = *((uint*) sptr.get());
std::cout << "[Evolve] Info: Loaded \"osc.maxoffset\"="<< max_offset << std::endl;
//-- Max phase:
sptr = state->getRegistry()->getEntry("osc.maxphase");
int max_phase = *((uint*) sptr.get());
max_pha_0_5 = max_phase / 2.0;
std::cout << "[Evolve] Info: Loaded \"osc.maxphase\"="<< max_phase << std::endl;
//-- Max frequency:
sptr = state->getRegistry()->getEntry("osc.maxfrequency");
float max_frequency = *((float*) sptr.get());
max_freq_0_5 = max_frequency / 2.0;
std::cout << "[Evolve] Info: Loaded \"osc.maxfrequency\"="<< max_frequency << std::endl;
//-- Create and configure the robot parts
//---------------------------------------------------------------------------------------
//-- Read test data
if ( configParser.parse(config_file) != 0)
{
std::cerr << "[Evolve] Error: error parsing xml config file!" << std::endl;
return false;
}
if ( configParser.getNumModules() != n_modules )
{
std::cerr << "[Evolve] Error: number of modules not consitent between config file and "
<< "robot model." << std::endl;
return false;
}
//-- Create robot, simulated type
robotInterface = createModularRobotInterface( "simulated", configParser);
//-- Create sinusoidal oscillators with the test parameters
oscillators.clear();
for ( int i = 0; i < configParser.getNumModules(); i++)
oscillators.push_back(new SinusoidalOscillator( 0, 0, 0, 4000));
robotInterface->reset();
return true;
}
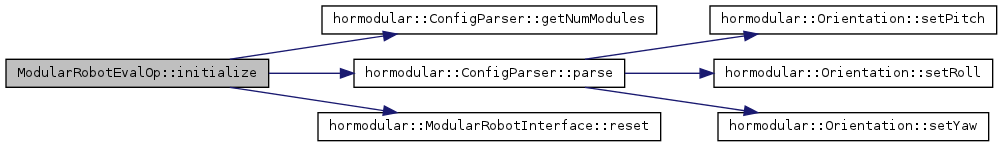
Here is the call graph for this function:
 |
 1.7.4

