|
Hormodular 1.0
Locomotion gait discovery by using digital hormones on modular robots
|
|
Hormodular 1.0
Locomotion gait discovery by using digital hormones on modular robots
|
Function evaluator (objective function) for the Modular Robot. More...
#include <ModularRobotEvalOp.h>
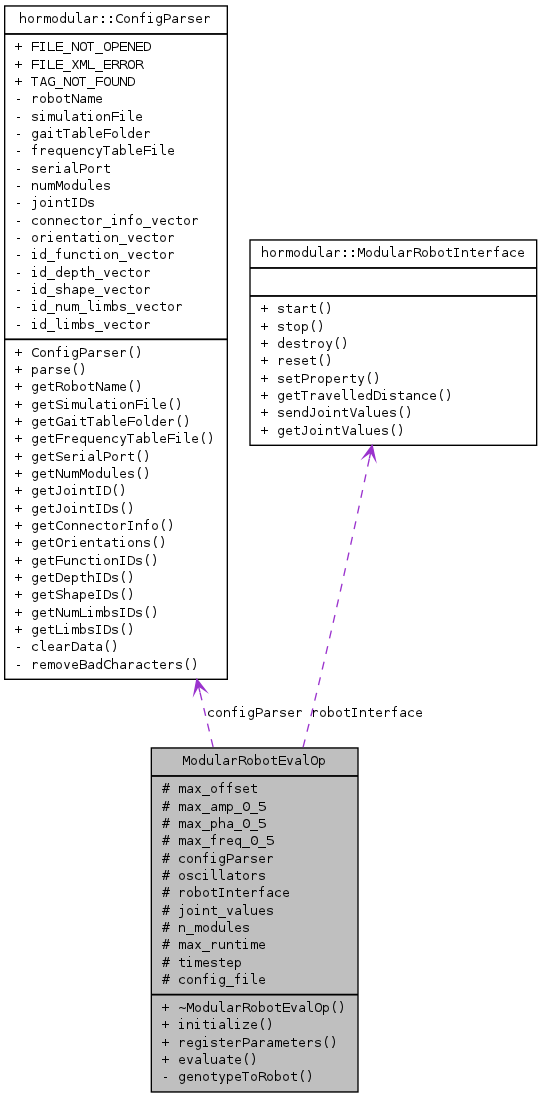
Public Member Functions | |
| ~ModularRobotEvalOp () | |
| bool | initialize (StateP state) |
| Loads custom-made registry entries to the ECF. | |
| void | registerParameters (StateP state) |
| This adds the custom-made registry entries to the ECF. | |
| FitnessP | evaluate (IndividualP individual) |
| Objective function. | |
Protected Attributes | |
| int | max_offset |
| float | max_amp_0_5 |
| float | max_pha_0_5 |
| float | max_freq_0_5 |
| ConfigParser | configParser |
| std::vector< Oscillator * > | oscillators |
| ModularRobotInterface * | robotInterface |
| std::vector< float > | joint_values |
| int | n_modules |
| unsigned long | max_runtime |
| float | timestep |
| std::string | config_file |
Private Member Functions | |
| void | genotypeToRobot (FloatingPoint::FloatingPoint *genotype) |
| Extract the oscillator parameters encoded in the genotype and set them in the oscillators. | |
Function evaluator (objective function) for the Modular Robot.
 1.7.4

