|
Hormodular 1.0
Locomotion gait discovery by using digital hormones on modular robots
|
|
Hormodular 1.0
Locomotion gait discovery by using digital hormones on modular robots
|
Abstract class that serves as a base to create different oscillators. More...
#include <Oscillator.h>
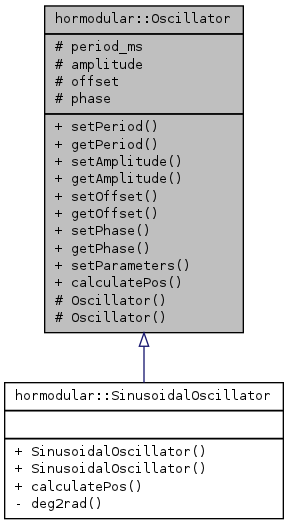
Public Member Functions | |
| void | setPeriod (int period_ms) |
| int | getPeriod () |
| void | setAmplitude (float amplitude) |
| float | getAmplitude () |
| void | setOffset (float offset) |
| float | getOffset () |
| void | setPhase (float phase) |
| float | getPhase () |
| void | setParameters (float amplitude, float offset, float phase, int period_ms=0) |
| Set all the oscillator parameters at once. | |
| virtual float | calculatePos (unsigned long time)=0 |
| Calculate the position of the oscillator at time. | |
Protected Member Functions | |
| Oscillator () | |
| Oscillator (float amplitude, float offset, float phase, int period_ms=4000) | |
Protected Attributes | |
| int | period_ms |
| float | amplitude |
| float | offset |
| float | phase |
Abstract class that serves as a base to create different oscillators.
 1.7.4

