|
Hormodular 1.0
Locomotion gait discovery by using digital hormones on modular robots
|
|
Hormodular 1.0
Locomotion gait discovery by using digital hormones on modular robots
|
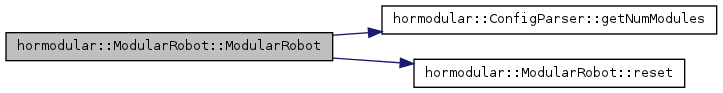
Creates a ModularRobot, specifying the type of robot to be created.
{
    this->configParser = configParser;

    //-- Create as many modules as needed
    for(int i = 0; i < configParser.getNumModules(); i++)
        modules.push_back( new Module(configParser, i) );

    //-- Create robot, simulated type
    robotInterface = createModularRobotInterface( robotInterfaceType, configParser);

    step_ms = 0.25;

    reset();
}
Here is the call graph for this function:
 |
 1.7.4

