|
Hormodular 1.0
Locomotion gait discovery by using digital hormones on modular robots
|
|
Hormodular 1.0
Locomotion gait discovery by using digital hormones on modular robots
|
Modular robot for modular robotics. More...
#include <ModularRobot.h>
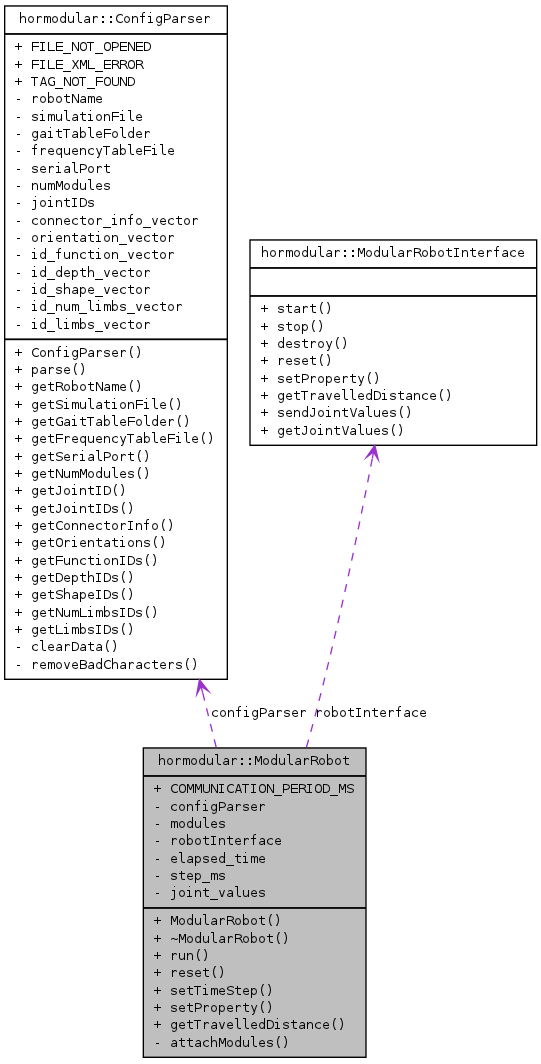
Public Member Functions | |
| ModularRobot (ConfigParser configParser, std::string robotInterfaceType="simulated") | |
| Creates a ModularRobot, specifying the type of robot to be created. | |
| ~ModularRobot () | |
| bool | run (unsigned long runTime) |
| Runs the modular robot distributed controller for a given amount of time. | |
| bool | reset () |
| Resets the initial state of the robot. | |
| bool | setTimeStep (float step_ms) |
| bool | setProperty (std::string property, std::string value) |
| float | getTravelledDistance () |
Static Public Attributes | |
| static const int | COMMUNICATION_PERIOD_MS = 100 |
Private Member Functions | |
| bool | attachModules () |
| Function that performs the connections between the different connectors of the different modules. | |
Private Attributes | |
| ConfigParser | configParser |
| std::vector< Module * > | modules |
| ModularRobotInterface * | robotInterface |
| unsigned long | elapsed_time |
| Time elapsed, expressed in us. | |
| float | step_ms |
| Simulation / robot communication step time, expressed in ms. | |
| std::vector< float > | joint_values |
Modular robot for modular robotics.
ModularRobot class contains all the modules that form the modular robot, and it is in charge of executing the modules controllers, emulating a concurrent distributed system.
 1.7.4

