|
Hormodular 1.0
Locomotion gait discovery by using digital hormones on modular robots
|
|
Hormodular 1.0
Locomotion gait discovery by using digital hormones on modular robots
|
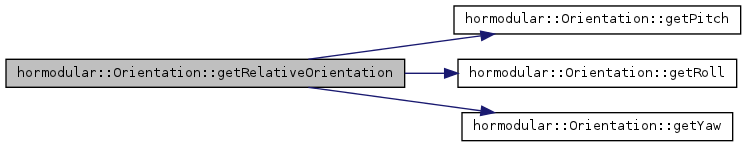
Returns the relative orientaion between two orientations, encoded as a number between 0 and 3. This number represents the number of 90º turns we have to rotate the local module around the axis of the local reference system that is in the same direction as the normal vector of the local connector surface, such as the Z axis of the local reference system of both modules coincide. {
//-- Create rotation matrices for local orientation:
Eigen::AngleAxisd rollAngle( deg2rad(localOrient.getRoll()), Eigen::Vector3d::UnitZ());
Eigen::AngleAxisd pitchAngle( deg2rad(localOrient.getPitch()), Eigen::Vector3d::UnitY());
Eigen::AngleAxisd yawAngle( deg2rad(localOrient.getYaw()), Eigen::Vector3d::UnitX());
Eigen::Quaterniond q0 = yawAngle * pitchAngle * rollAngle ;
Eigen::Matrix3d rotationMatrix = q0.matrix();
//-- Create rotation matrices for the other orientation:
Eigen::AngleAxisd otherRollAngle( deg2rad(remoteOrient.getRoll()), Eigen::Vector3d::UnitZ());
Eigen::AngleAxisd otherPitchAngle( deg2rad(remoteOrient.getPitch()), Eigen::Vector3d::UnitY());
Eigen::AngleAxisd otherYawAngle( deg2rad(remoteOrient.getYaw()), Eigen::Vector3d::UnitX());
Eigen::Quaterniond q1 = otherYawAngle * otherPitchAngle * otherRollAngle;
Eigen::Matrix3d otherRotationMatrix = q1.matrix();
Eigen::Matrix3d relativeRotation = rotationMatrix.inverse() * otherRotationMatrix;
Eigen::Vector3d new_z = relativeRotation * Eigen::Vector3d::UnitZ();
// std::cout << "New_z: " << std::endl << new_z << std::endl << std::endl;
//-- Get connector base vector for the rotations:
Eigen::Vector3d base_vector;
if ( connector == 0 || connector == 2)
{
//-- Y axis
base_vector = Eigen::Vector3d::UnitY();
}
else if ( connector == 1 || connector == 3)
{
//-- X axis
base_vector = Eigen::Vector3d::UnitX();
}
//-- Try for rotations to fit the vector
for ( int i = 0; i < 4; i++)
{
Eigen::AngleAxisd rotAngle( deg2rad(i*90), base_vector);
Eigen::Matrix3d rotMatrix = rotAngle.matrix();
Eigen::Vector3d result_vector = rotMatrix * Eigen::Vector3d::UnitZ();
// std::cout << "i = " << i << std::endl << result_vector << std::endl << std::endl;
if ( vector_equal(result_vector, new_z) )
return i;
}
return -1;
}
Here is the call graph for this function:
 |
 1.7.4

