|
Hormodular 1.0
Locomotion gait discovery by using digital hormones on modular robots
|
|
Hormodular 1.0
Locomotion gait discovery by using digital hormones on modular robots
|
Interface to the simulated robot. More...
#include <SimulatedModularRobotInterface.hpp>
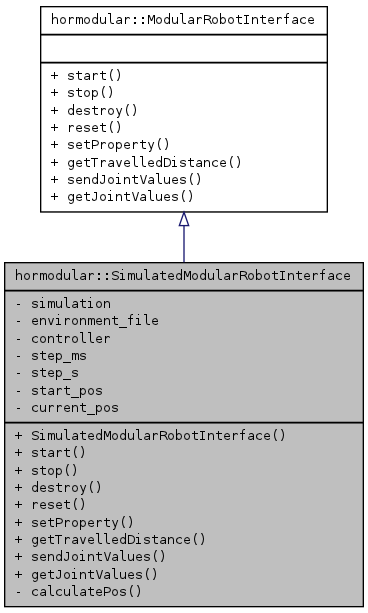
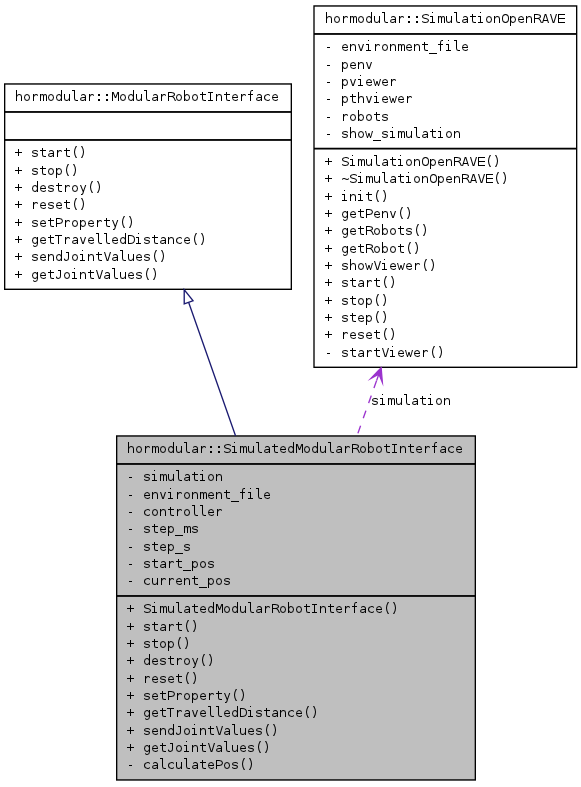
Public Member Functions | |
| SimulatedModularRobotInterface (ConfigParser configParser) | |
| virtual bool | start () |
| Starts the simulation. | |
| virtual bool | stop () |
| Stops the simulation. | |
| virtual bool | destroy () |
| Frees all the dynamically allocated memory. | |
| virtual bool | reset () |
| Resets the simulation, returning the robot to the initial position. | |
| virtual bool | setProperty (std::string property, std::string value) |
| Configure a property or parameter of the interface. | |
| virtual float | getTravelledDistance () |
| Returns the distance travelled by the simulated modular robot. | |
| virtual bool | sendJointValues (std::vector< float > joint_values, float step_ms=0) |
| Sends the specified joint position values to the simulated modular robot servocontroller. | |
| virtual std::vector< float > | getJointValues () |
| Returns the actual joint position values of the simulated modular robot. | |
Private Member Functions | |
| void | calculatePos () |
| Gets robot position and stores it on the current_pos variable. | |
Private Attributes | |
| SimulationOpenRAVE * | simulation |
| std::string | environment_file |
| OpenRAVE::ControllerBasePtr | controller |
| int | step_ms |
| double | step_s |
| std::pair< float, float > | start_pos |
| std::pair< float, float > | current_pos |
Interface to the simulated robot.
 1.7.4

