|
Hormodular 1.0
Locomotion gait discovery by using digital hormones on modular robots
|
|
Hormodular 1.0
Locomotion gait discovery by using digital hormones on modular robots
|
--
{
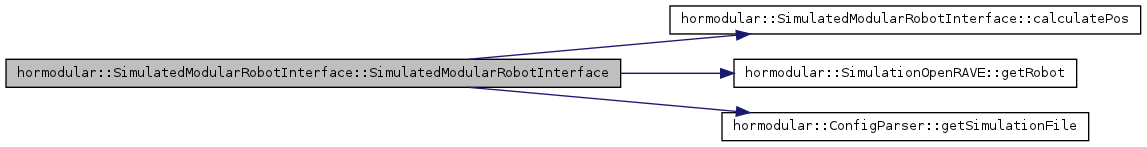
    environment_file = configParser.getSimulationFile();
    step_ms = 1;
    step_s = step_ms / (double)1000;

    simulation = new SimulationOpenRAVE( environment_file, false);

    controller = simulation->getRobot(0)->GetController();

    calculatePos();
    start_pos = current_pos;

}
Here is the call graph for this function:
 |
 1.7.4

