|
Hormodular 1.0
Locomotion gait discovery by using digital hormones on modular robots
|
|
Hormodular 1.0
Locomotion gait discovery by using digital hormones on modular robots
|
Base class for different types of modules for modular robotics. More...
#include <Module.hpp>
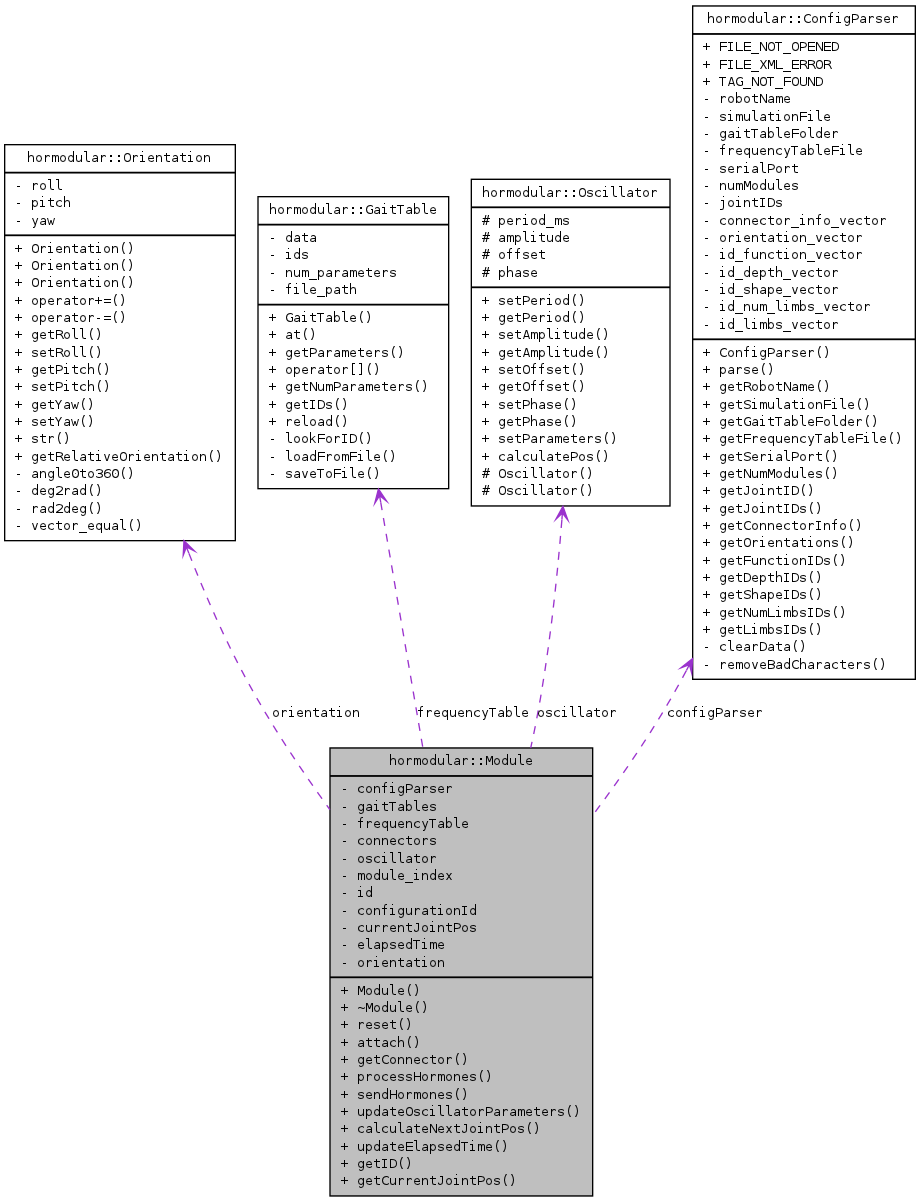
Public Member Functions | |
| Module (ConfigParser configParser, int index) | |
| Creates a Module, indicating which position it occuppies inside the modular robot. | |
| ~Module () | |
| bool | reset () |
| Resets the module to its initial state. | |
| bool | attach (int localConnector, Connector *remoteConnector, int orientation=-1) |
| Connects a connector from this module to other connector from other module. | |
| Connector * | getConnector (int localConnector) |
| bool | processHormones () |
| Process the incoming hormones, and discover the different module IDs from them. | |
| bool | sendHormones () |
| Send the hormones in the output buffer to their destination modules. | |
| bool | updateOscillatorParameters () |
| Gets the parameters for the current module IDs and sets them on the oscillator. | |
| float | calculateNextJointPos () |
| Returns the next joint position according to the current elapsed time. | |
| bool | updateElapsedTime (float timeIncrement_ms) |
| updateElapsedTime | |
| unsigned long | getID () |
| float | getCurrentJointPos () |
Private Attributes | |
| ConfigParser | configParser |
| std::vector< GaitTable * > | gaitTables |
| GaitTable * | frequencyTable |
| std::vector< Connector * > | connectors |
| Oscillator * | oscillator |
| int | module_index |
| unsigned long | id |
| int | configurationId |
| float | currentJointPos |
| unsigned long | elapsedTime |
| Orientation | orientation |
Base class for different types of modules for modular robotics.
 1.7.4

